What Are the Top 10 Types of Brushless Motors?
A brushless motor is not a single design, but a family of machines with different magnetic layouts, controls, and operating strengths. Some deliver steady torque at low speeds. Others prioritize compact dimensions, quiet operation, or high rotational speed. The differences matter when selecting a motor for a drone, pump, power tool, or factory drive.
R. Krishnan, a researcher and author on brushless motor drives, provides a technical foundation for understanding these machines. The following line is an editorial summary of that engineering perspective, not a verified direct quotation: “Match the motor’s electromagnetic design and control method to the load.” It sounds simple. In practice, heat, available space, speed range, and controller compatibility can complicate the choice.
This guide examines ten commonly discussed types, including inrunner and outrunner designs, slotless motors, coreless motors, axial-flux motors, and sensor-based or sensorless configurations. These labels do not all describe the same feature; some refer to construction, while others describe control or rotor arrangement. That distinction is easy to miss. A motor may fit more than one category, so the list is a practical map, not a strict taxonomy. Each section explains how a type works, where it can perform well, and what trade-offs to check before choosing one. The comparison should help readers ask better questions—not promise that one design suits every application.
Brushless Motor Structure and Electronic Commutation
What Are the Top 10 Types of Brushless Motors?
Brushless Motor Structure and Electronic Commutation
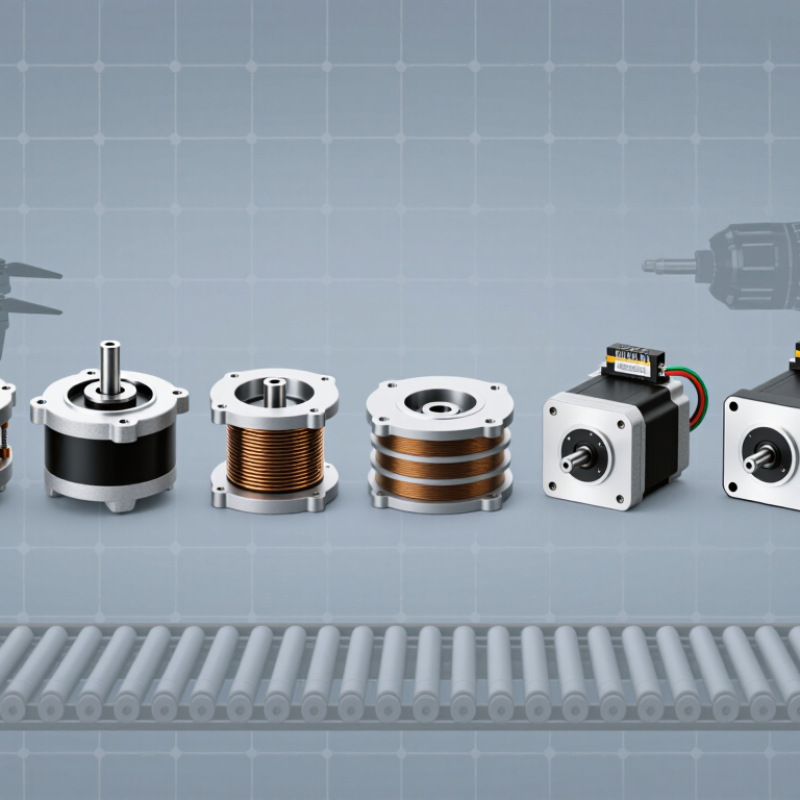
Brushless motors replace mechanical brushes with electronic switching. Their rotor carries permanent magnets; copper windings sit in the stator. Ten common labels are inrunner, outrunner, radial-flux, axial-flux, slotless, and coreless designs. Others describe control: sensored, sensorless, trapezoidal BLDC, and sinusoidal PMSM. These labels overlap; they are not ten mutually exclusive families. Small detail. Big effect.
An inverter energizes stator phases in sequence, pulling the magnetic rotor around without physical contact. Hall sensors report rotor position; sensorless drives estimate it from back electromotive force. At low speed, that estimate can be less reliable. Control may use six-step commutation or field-oriented control, which adjusts current more smoothly. The right choice depends on speed range, torque, noise, cooling, and cost—not a label alone.
The International Energy Agency’s 2011 report, Energy-Efficiency Policy Opportunities for Electric Motor-Driven Systems, estimates motor-driven systems use about 45% of global electricity. That figure is not specific to brushless motors, but it shows why system efficiency matters. A well-built motor can still waste energy if its controller is poorly matched. In practice, engineers should check performance across the actual load range, not just the peak-efficiency point. I would not treat that single number as a design promise.
| # | Type | Structure or Classification | Typical Electronic Commutation | Common Uses | Key Consideration |
|---|---|---|---|---|---|
| 1 | Inner-Rotor Radial-Flux Motor | The permanent-magnet rotor sits inside the stator; magnetic flux crosses the air gap radially. | Typically a three-phase inverter using Hall sensors, an encoder, or sensorless position estimation. | Industrial drives, pumps, power tools, and vehicle traction systems. | Often supports high rotor speeds and effective cooling, but may require gearing when high output torque at low speed is needed. |
| 2 | Outer-Rotor Radial-Flux Motor | The rotor surrounds the stator, placing magnets on the inside of the rotating outer shell. | Commonly electronically commutated with Hall sensors or sensorless control. | Fans, small direct-drive equipment, and some lightweight mobility applications. | The larger rotor radius can provide useful torque at low speed; the rotating outer shell affects packaging and inertia. |
| 3 | Axial-Flux Motor | Magnetic flux travels parallel to the shaft; rotor and stator surfaces are generally disk-shaped. | Usually driven by a three-phase inverter with position feedback or sensorless control. | Compact traction drives, pumps, and applications with limited axial space. | Can offer a short axial package, but thermal management, mechanical stiffness, and air-gap control are important design challenges. |
| 4 | Slotted Brushless Motor | Stator windings are placed in teeth and slots in a laminated iron core. | May use six-step trapezoidal commutation or sinusoidal field-oriented control. | Industrial machinery, appliances, and general-purpose motion systems. | Slots help concentrate magnetic flux, while slotting can contribute to cogging torque and torque ripple. |
| 5 | Slotless Brushless Motor | The winding is arranged without conventional stator teeth or slots, typically around a smooth magnetic core structure. | Often controlled with sinusoidal current; suitable controllers can also use other commutation strategies. | Precision instruments, compact pumps, and low-noise motion applications. | Typically has low cogging torque and smooth rotation; continuous torque and heat dissipation depend strongly on the design. |
| 6 | Trapezoidal-Commutated BLDC Motor | A permanent-magnet synchronous motor design commonly paired with back-EMF and winding arrangements suited to six-step operation. | Six-step commutation energizes two phases at a time, with the third phase commonly left unpowered during each step. | Fans, pumps, and cost-sensitive variable-speed drives. | Control can be relatively simple; torque ripple and acoustic noise may be more noticeable than with well-tuned sinusoidal control. |
| 7 | Sinusoidally Commutated PMSM | A permanent-magnet synchronous motor designed or operated for approximately sinusoidal phase currents and back-EMF. | Commonly uses sinusoidal PWM or field-oriented control with rotor-position feedback or estimation. | Servo systems, robotics, electric vehicles, and efficient variable-speed drives. | Can provide smooth torque and precise control, but typically requires more capable control electronics and tuning. |
| 8 | Hall-Sensored Brushless Motor | A brushless motor fitted with Hall-effect sensors that detect rotor magnetic position. | The controller uses sensor signals for phase switching, especially at low speeds and during startup. | Applications requiring reliable startup or operation at low speed. | Provides direct rotor-position information, but adds wiring and sensors that must be installed and aligned correctly. |
| 9 | Sensorless Brushless Motor | A brushless motor without dedicated rotor-position sensors; the controller estimates rotor position from electrical measurements. | Methods include back-EMF zero-crossing detection and model-based estimation; the chosen method depends on the drive. | Fans, pumps, and other applications where reduced wiring or lower sensor count is desirable. | Can simplify motor hardware, but some methods have limited position information at standstill or very low speed. |
| 10 | Brushless Hub Motor | A brushless motor integrated into a wheel hub, commonly using an outer-rotor arrangement. | Usually driven by a three-phase controller with Hall-sensored or sensorless commutation. | Electric bicycles, scooters, and other compact wheel-drive systems. | Direct wheel drive can reduce transmission parts; wheel mass, heat dissipation, and service access should be considered. |
Note: These categories describe different aspects of brushless motors—rotor layout, magnetic-flux direction, stator construction, commutation method, sensing, or integration. They overlap and are not mutually exclusive; for example, a hub motor can also be an outer-rotor motor.